dingkaihu63/dsh-robotic-harness
robotic-harness-dsh
Robotic Harness: embodied-intelligence research tools for DeepSeek Harness - robot asset inspection, MuJoCo pick-place simulation with fault injection, evidence-based diagnostics, and reproducible experiment bundles.
Install
npx @deepseek-ai/dsh plugin --profile rh-demo add ./packages/dsh-bundleRestart `dsh web` after install. Bundle APIs can change during the developer preview.
README badge
[](https://dshhub.dev/plugins/dsh-robotic-harness)Paste this into your README. The star count updates with every catalog sync.
From the README
Excerpt from dingkaihu63/dsh-robotic-harness, cleaned of badges and images.
🤖 Robotic Harness
An embodied-intelligence research plugin suite for DeepSeek Harness
Put robot assets, simulation, capability orchestration and failure evidence into one Agent workflow — from CAD/URDF inspection to MuJoCo pick-and-place, fault injection, evidence-based diagnostics and reproducible experiment bundles.
🧪 Testers & contributors: this project is at an early Demo stage. It has been validated only in a limited local environment (Windows + Anaconda Python 3.10 + DSH 0.1.0-rc.6). ROS 2, CAD, real-robot and other OS/hardware setups have not been fully tested — please forgive rough edges and report any issues you hit. Everyone is welcome to test, modify and extend this plugin suite, and to combine your own robot-related plugins (ROS 2 / CAD / vision / control / VLA / ...) with this suite to build one bigger, complete robot plugin bundle together — every independent module can be published and contributed separately. See CONTRIBUTING.md.
📑 Table of contents
- ✨ Features
- 📸 Screenshots
- 🚀 Quick start (30 seconds)
- 🏗️ Architecture
- 📦 Install as a DSH plugin
- 🧩 Tool & skill surface
- 🎯 The demo (MuJoCo pick-and-place)
- ⚠️ Known limitations
- 🌊 Future vision
- 📂 Repository layout
- 📚 Documentation
- 🤝 Contributing
- 📄 License
✨ Features
| 🔍 Assets & CAD | URDF / MJCF / SDF inspection, inertia & topology validation, mesh stats, SVG preview, URDF→MJCF conversion, SDF-compat export, CAD inventory & version compare |
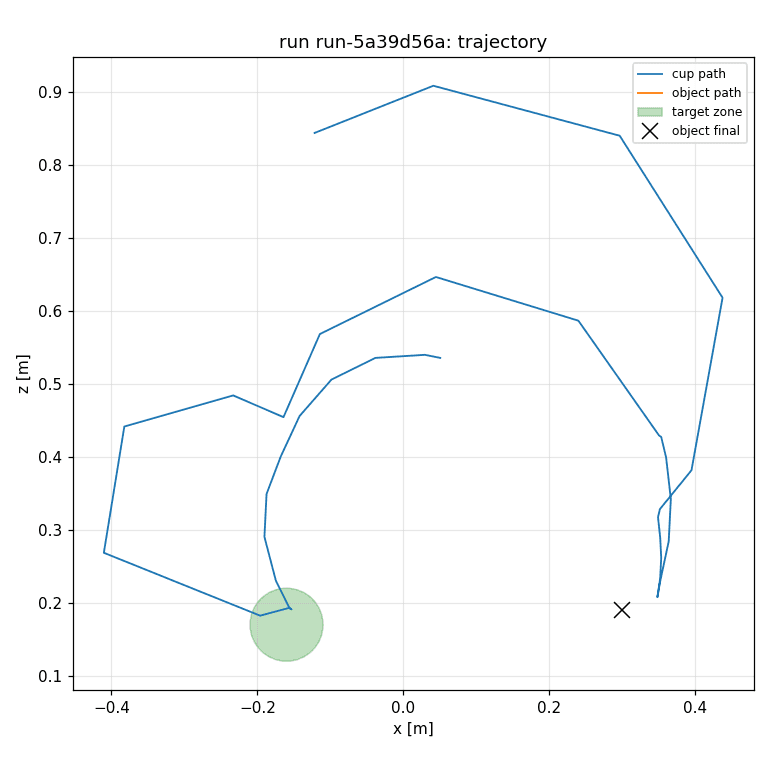
| 🎮 Simulation | MuJoCo pick-and-place with 6 fault-injection modes, batch benchmarks, read-only replay, sim-vs-real gap reports |
| 🧮 Control | Tracking metrics (rise/settle/overshoot/SSE), trajectory validation, planned-vs-actual compare, PID templates & config compare, system identification |
| 👁️ Vision | Color/generic perception routing, camera health, calibration inspection, pose checks, perception comparison, failure-frame annotation |
| 🧠 Embodied models | Model registry, builtin demo adapters (run for real), honest backend probes, rule-based capability routing, policy rollout compare |
| 📡 Telemetry & diagnostics | Deterministic rule engine (facts / rules / hypotheses), anomaly scan, failure-evidence collection, run compare |
| 🧬 Data pipeline | Inventory, schema, time-sync, alignment, non-destructive transforms, episodes, leakage-safe splits, de-identification, rosbag conversion, LeRobot export, dataset versions & cards |
| 🔬 Experiments | Spec → matrix → benchmark → metrics → ablation → report |
| 🤖 Real-robot flow | Preflight checklist + experiment state machine (hardware items skipped honestly without an adapter) |
| 📚 Knowledge | Docs index/search, error-code lookup, diagnostic-case search, project memory (retrieve/ingest) |
| 📖 Research | Literature search (arXiv / Semantic Scholar) + problem→solution proposals with evidence for any stage |
| 🚀 Autonomous training | Server check → training plan → supplementary dataset discovery → job prepare (dry-run default) → confirmed remote submit → status → report |
| 📊 **R |
…